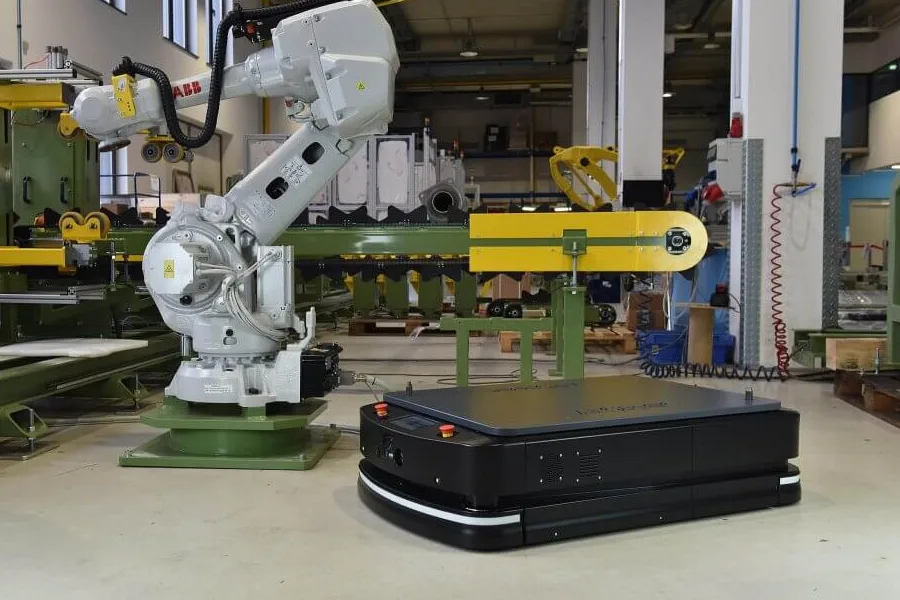
An AGV battery charging system combines a charger, a compatible battery and BMS, and the charging point where the vehicle connects or parks. Choose the charging method, calculate the energy to recover during available stops, then check battery limits and integration requirements together.
This guide compares manual plug-in charging, automatic contact docking, battery swapping and wireless opportunity charging. It then explains how AGV battery systems are assembled, how chemistry and voltage affect charger selection, and how to size charging power from route energy, dwell time and the battery management system (BMS) limit.
Start here: compare the charging methods below, work through the sizing example, then discuss your charging requirements with ONEPOINTECH.
AGV battery charging systems at a glance
| Charging method | Automation | Main advantage | Main constraint | Best fit |
|---|---|---|---|---|
| Manual plug-in | Low | Simple and inexpensive to start | Requires labor and charging downtime | Small, single-shift fleets |
| Automatic contact docking | High | Efficient conductive transfer | Contacts need accurate docking, cleaning and eventual replacement | Clean facilities with repeatable docking |
| Battery swapping | Medium to high | Returns a vehicle to service quickly | Needs spare batteries, handling equipment and inventory | Very high-energy or round-the-clock duty |
| Wireless charging | High | No exposed charging contacts; charges during planned stops | Power, coil gap, alignment and station placement must be engineered together | Automated multi-shift AGV and AMR fleets |

Opportunity charging is a schedule, not a charging interface. Both conductive and wireless systems can recharge during planned stops when the battery and controls permit it.
For fleets that already stop at loading, transfer or parking positions, AGV wireless charging systems can turn those dwell periods into automatic charging time. The comparison above is a screening tool; final selection must still be checked against the battery charge profile, permitted current and operating schedule.
How the charger, battery and charging point fit together
An AGV battery charging system is not a single product. It is three parts that have to be sized against each other:
- The charger — the unit that converts site power into the current and voltage the pack accepts, whether that is a conventional charger on a cable or a wireless transmitter driving a coil.
- The battery — the pack and its BMS, which set the real ceiling on accepted current and the voltage window the charger has to follow.
- The charging point — where the vehicle physically connects or parks: a bay, a dock, or a floor pad at a stop the vehicle already makes.
A common specification risk is treating those as three separate purchases. A charger chosen on its label power, a battery chosen on capacity, and a charging point placed wherever there happened to be room will not necessarily work together. The battery's BMS current limit can cap a charger well below its rating, and a pad in the wrong position costs more in detour time than a higher-power charger ever saves.
So the specification runs backwards from what most teams expect. Start with the energy the vehicle has to recover and the time it can spend charging, derive the required current, check that current against the pack's BMS limit, and only then choose a charger and place the charging point. The charging power guide works through that calculation, and the sizing section below applies it to a worked example.
AGV battery systems: chemistry, voltage and capacity
An AGV battery system is the vehicle-side assembly that stores and manages energy: the cell pack, the battery management system (BMS) that protects and balances it, and the charge interface the vehicle exposes to a charger. All three are specified together, because each one constrains the others.
Lead-acid, LiFePO4 and NMC are battery options used in industrial vehicles. Compare the specific pack’s documented charging profile, temperature range, cycle-life test conditions and maintenance needs instead of assigning a fixed service life to its chemistry.
| Chemistry | Key characteristics | Best for |
|---|---|---|
| Lead-acid | Check the specified full-charge, equalization, ventilation and maintenance requirements for the battery type. Partial-state-of-charge operation requires supplier approval. | Single-shift operations that can park overnight. |
| Lithium iron phosphate (LiFePO4) | Check permitted current, operating temperature, charging-voltage range and BMS settings. Frequent partial charging must fit the pack specification. | Projects whose pack specification supports the planned charging schedule. |
| Nickel-manganese-cobalt (NMC) | Evaluate the specific pack’s energy density, thermal management, permitted charge current and state-of-charge limits. | Projects where payload weight is the constraint. |
Common nominal voltages include 24V, 36V and 48V. They are examples, not compatibility rules; platform requirements vary:
- 24 V — light AMRs, carts and small carriers.
- 36 V — middle-weight platforms and automated tugger trains.
- 48 V — the workhorse for pallet movers, heavy AGVs and forklift platforms: a higher voltage moves the same power at lower current, shrinking cables, connectors and losses.
Automated tugger trains deserve their own note, because they break the voltage pattern. A tractor unit pulling several loaded carts draws far more energy than its 24 V or 36 V class suggests, and the load changes with every trip — an empty return leg costs a fraction of a loaded one. Size the battery system on the worst realistic train and route rather than the average, or the vehicle will finish the shift short.
Capacity is the third variable, and it is usually set by the charging strategy rather than by shift length. A fleet running opportunity charging may be able to use a smaller pack if measured energy recovery and operating reserve cover the intervals between stops, including missed charging events. A fleet charging once per shift needs a pack sized for the whole shift plus reserve.
Whatever the voltage, the pack is a series stack of cells, so the BMS charge limit — not the charger's label — sets the true ceiling on how fast the battery can accept energy. For a full comparison of chemistries, see our guide to battery types, and for the charger side of the same question, see which batteries a wireless charging system can charge.
Charge cycles: full charging vs. opportunity charging
The two charging models differ in when the vehicle charges, how the pack is treated, and what the fleet gains:
| Full charging | Opportunity charging | |
|---|---|---|
| When it charges | The vehicle runs until its working state of charge is spent, then sits off-line for one controlled charge back to the BMS target at the end of the shift. | Short, automatic top-ups at the natural stops in the workflow, so the pack spends the day in a mid-range state of charge instead of swinging to near-empty and back. |
| Battery impact | Battery impact depends on depth of discharge, current, temperature and supplier-required balancing or full-charge procedures. | Requires a pack-approved partial-charge profile; chemistry alone does not establish suitability. |
| Fleet trade-off | Simple to engineer; the vehicle is out of service for the full charge. | May reduce dedicated charging time or battery capacity if the energy balance supports it; station availability and reserve must be validated. |
That availability trade-off is the real decision. Choose the battery and charging schedule together using the supplier’s limits and measured fleet duty cycle. For the full treatment of availability, station counts and battery-level behavior, see our guide to Opportunity Charging for AGV and AMR Fleets.
How to size a charger for an AGV fleet
Charger sizing starts from energy, not wattage. Three numbers define the problem:
- The battery capacity, in watt-hours.
- The energy the vehicle actually consumes per mission.
- The time the vehicle can spend at a charging point.
The required average power is the energy to be replaced divided by the charging window. Worked example:
| Input | Value |
|---|---|
| Battery pack | 48 V, 200 Ah = 9.6 kWh |
| Energy burned per mission | 1.2 kWh |
| Time at the dock | 10 minutes (0.167 h) |
| Required average power | 1.2 kWh ÷ 0.167 h ≈ 7.2 kW |
This is a hypothetical battery-side requirement, not a recommendation for a listed product. Recovering 1.2kWh in ten minutes requires 7.2kW average at the battery. That exceeds the maximum 6kW rating of the complete systems linked here, before considering their voltage/current limits or charge taper. Change the charging time, number of stops, route energy or system requirement rather than selecting a lower-power charger and assuming it will recover the same energy.
Check voltage, current and actual delivered power
At an illustrative battery terminal voltage of 48V, a 100A charger limit caps output at 48 × 100 ÷ 1,000 = 4.8kW, even if the system is rated up to 6kW. A 60A limit at that voltage gives 2.88kW. Check the charger operating curve and battery charge profile across the full voltage range.
For a feasible planning example, assume a validated average of 2.4kW delivered to the battery for 15 minutes: 2.4 × 0.25 = 0.6kWh. At a constant illustrative 48V, 2.4kW corresponds to 50A. This is an assumed operating point, not a product performance promise; confirm voltage, current, temperature, taper and the actual time power is flowing.
Use battery-side energy ÷ charging time for average delivered power. If calculating from site input power, include measured conversion losses. Do not apply efficiency again to power already measured at the battery. Use the industrial charging power calculator for an initial estimate.
Two practical constraints also need review:
- BMS charge limit — sets the maximum pack current, and therefore the real power ceiling.
- State-of-charge window — a pack cycled between 30% and 80% requires far less energy per session than a full 0–100% cycle.
Size the charger to the recovery window that actually recurs in the route, then confirm the pack and BMS can accept the resulting current continuously. For the full worked method, including voltage, current and C-rate limits, see How to Choose Charging Power for AGV and AMR Batteries.
Wireless AGV charging: how it works
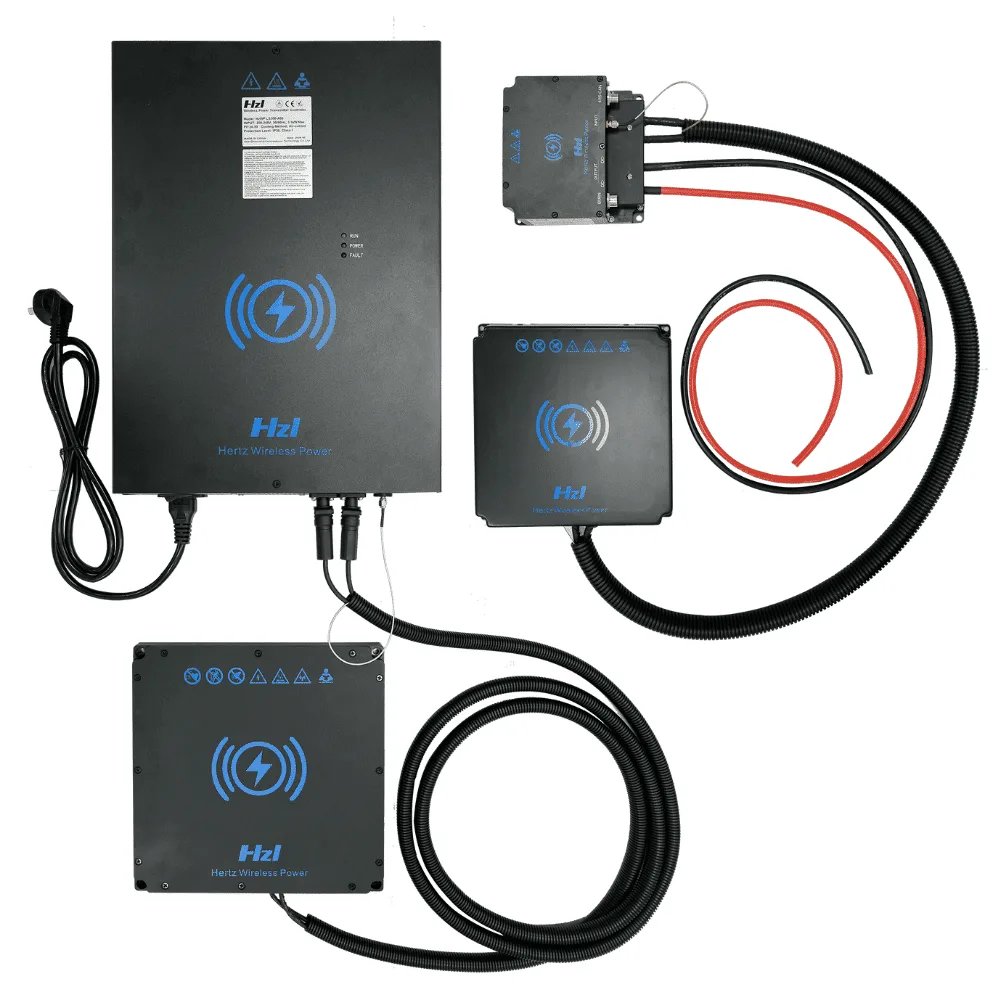
A wireless AGV charger transfers power inductively between two coils: a transmitter pad fixed to the floor or wall, and a receiver coil mounted on the vehicle. The transmitter drives an alternating magnetic field; receiver electronics rectify and regulate the coupled power into DC output for the battery. Charging control must match the battery profile and BMS requirements.
Two mechanical numbers govern the design:
- Air gap — the distance between the coil faces.
- Docking tolerance — the lateral and angular misalignment the system can absorb while holding rated power.
Larger gaps and looser tolerances cost coupling efficiency and coil size, so a realistic docking-accuracy target matters more than peak efficiency on paper. Efficiency depends on the model, gap, alignment, load and measurement boundary. Compare model-specific documentation and measure performance over the intended operating window.
Wireless charging removes the exposed mating contacts at the charging interface. It does not make the complete installation maintenance-free, suitable for wash-down or approved for hazardous areas. Check enclosure ratings component by component, along with cleaning, thermal, impact and site requirements.
AGV charging station design considerations
Station design begins with placement: put the pad where the vehicle already stops — loading docks, conveyor transfer points, staging zones — so charging time comes free from the workflow instead of costing a detour. The engineering detail follows in two layers:
- Alignment and environment — the pad must sit flat enough that the vehicle's docking accuracy keeps the receiver inside the coil's tolerance zone, and the site must absorb the real conditions — dust ingress, humidity, wash-down, cleanroom particle control, floor joints — which drive the enclosure rating and mounting method.
- Integration — the charger should talk to the vehicle controller or BMS over CAN or RS485, so charging starts and stops on the fleet's schedule rather than on a timer, and fault and status signals reach the fleet management system.
For the complete design methodology, including docking types and safety protection, see our AGV Charging Station Design guide, and for a vehicle-side specification checklist see the AMR Charging Station Specification Guide.
Specifying a charger for your project
Before you request a quote, gather the numbers the design depends on:
- AGV or AMR type
- Battery chemistry, nominal voltage, full charging-voltage range and capacity
- Maximum permitted charge current, charging profile and BMS protocol
- Charging window available at each stop
- Docking accuracy the vehicle can hold
- Air gap to the receiver
- Operating environment
- Required communication interface
- Target quantity and project timeline
Send those requirements and the battery datasheet for a compatibility review before choosing a model. Discuss Your Charging Requirements using the existing engineering inquiry form; no power class needs to be selected in advance.
Working on an AGV or AMR fleet project? First compare the 1.5kW, 3kW and 6kW AGV wireless charging systems, or request a technical review using the quote button below. Include your battery voltage, permitted current, charging window and expected quantity.