AMR wireless charging transfers power from a stationary transmitter to a receiver on an autonomous mobile robot without exposed charging contacts. It can automate charging at a dedicated dock or a repeatable process stop, provided the battery limits, coil alignment and available charging time are engineered together.
For robotics OEMs and fleet integrators, selection starts with the energy the robot must recover, the charging voltage and current its battery accepts, and the space available for the receiver. Wireless charging can reduce contact-related maintenance; it still requires validated docking, thermal management and coordinated charger controls.
This guide explains automatic charging, compares contact and wireless interfaces, and outlines how to evaluate modules and complete systems from the industrial wireless charging range.

What Is AMR Wireless Charging?
AMR wireless charging is a contactless power transfer system designed for autonomous mobile robots. It usually includes a fixed transmitter installed on the floor, wall, docking station, or charging position, and a receiver module installed inside or underneath the robot.
When the AMR reaches the charging position, the transmitter and receiver coils align within a designed air gap. Power transfers through an electromagnetic field from the transmitter side to the receiver side. Receiver electronics convert the transferred energy into DC output. The output voltage, current and charging profile must match the battery requirements; a BMS is not a substitute for a compatible charger.
A typical AMR wireless charging system includes:
| Component | Function |
|---|---|
| Transmitter power supply | Provides input power to the charging station |
| Transmitter controller | Controls power transfer, protection, and communication |
| Transmitter coil | Sends energy across the air gap |
| Receiver coil | Receives energy on the robot side |
| Receiver power module | Converts received energy into usable DC output |
| Battery / BMS connection | Connects the charger to the battery; the charging profile and BMS limits must be coordinated |
| Communication interface | Optional status, control, and safety communication |
For AMR projects, the most important design questions are not only “Can it charge?” but also:
- How much charging power does the robot need?
- How much air gap is available?
- How accurately can the robot align with the charging pad?
- Does the charger need to communicate with the BMS?
- Will the system work in dusty, wet, cold, hot, or high-vibration environments?
- What certifications or compliance documents are needed?
Why AMRs Need Automatic Charging
AMRs are often used in environments where uptime matters: warehouses, production lines, hospitals, laboratories, semiconductor facilities, and logistics centers. If a robot needs frequent manual charging, the automation value is reduced.
Traditional charging methods can create several problems:
- Manual charging requires workers to find, park, and connect the robot.
- Plug-in connectors wear out over time.
- Exposed contacts can collect dust, oil, water, or debris.
- Docking contacts may fail if the robot is misaligned.
- Long charging breaks interrupt fleet availability.
- Cable charging creates safety and workflow problems in busy facilities.
Wireless charging removes the physical charging contact. The AMR only needs to reach the charging area and align within the system’s tolerance. This makes charging easier to automate and better suited for robots that operate for long hours.
How AMR Wireless Charging Works
The charging process usually follows five steps.
First, the AMR receives a charging command from its fleet management system or decides to charge based on battery level.
Second, the AMR navigates to a charging location. This can be a dedicated charging station, a natural waiting area, a loading/unloading point, or a parking zone.
Third, the robot aligns its receiver coil with the transmitter coil. Depending on the system design, this alignment may be floor-based, wall-mounted, side-mounted, or built into a docking structure.
Fourth, charging starts only after the configured receiver-detection and charge-enable conditions are satisfied. Specify the required protections and interlocks for the selected model, including its behavior under misalignment or a fault.
Fifth, the receiver delivers DC output within the approved battery charging envelope. Where communication is configured, the charger and robot controller or BMS exchange charging state, limits and faults. Define a safe stop on loss of communication and prevent vehicle departure until charging is disabled.

Opportunity Charging for AMR Fleets
Opportunity charging means the robot charges during short available moments instead of waiting for one long charging session. For example, an AMR may charge while waiting at a loading station, while parked between missions, or during short idle periods in the workflow.
This is one of the strongest reasons to use wireless charging for AMRs.
Short automatic sessions can reduce dedicated charging time if their accumulated battery-side energy covers route consumption and operating reserve. The battery supplier must approve the charging profile, current and state-of-charge window. Use the opportunity charging planning guide to evaluate stop locations and fleet scheduling.
Opportunity charging is especially useful when:
- AMRs operate in multiple shifts
- Robots have frequent short idle periods
- Manual charging is difficult or expensive
- The robot fleet must stay available for 24/7 operation
- Charging contacts are unreliable in the working environment
- The facility wants to reduce battery size or avoid battery swapping
Wireless Charging vs Contact Charging for AMRs
Both wireless charging and contact charging can be automated, but they are not the same.
| Factor | Wireless Charging | Contact Charging |
|---|---|---|
| Physical connection | No exposed charging contact | Requires metal contacts or pins |
| Maintenance | Eliminates wear at the charging contact; other components still require inspection | Contacts may wear, oxidize, or collect dirt |
| Alignment | Needs coil alignment within tolerance | Needs mechanical contact alignment |
| Environment | Can remove exposed contacts; enclosure ratings and cleaning conditions still need validation | More sensitive to dirty contacts |
| Safety | No exposed live charging pins during normal use | Depends on contact design and protection |
| Integration | Requires transmitter/receiver coil design | Requires contact design and docking mechanism |
| Best for | Autonomous, sealed, high-use AMRs | Lower-cost systems with simple docking needs |
Wireless charging is not always the cheapest option. But for AMRs where uptime, sealed design, clean operation, or low maintenance matters, it can be the better long-term choice.
How to Choose AMR Wireless Charging Power
The right charging power depends on battery voltage, battery capacity, working time, idle time, and charging strategy.
A small AMR may only need a lower-power charging module if it has frequent idle time and a smaller battery. A larger AMR carrying heavier payloads may need a higher-power wireless charging system, especially if it has short charging windows and long operating hours.
A basic way to think about power selection is:
Required charging power depends on:
Battery capacity
Target charge time
Available opportunity charging time
Battery charging current limit
System efficiency
Thermal design
For example, if an AMR only stops for short periods, the charger may need higher power to make each stop useful. If the AMR has longer parking periods, a lower-power charger may be enough. Calculate charging power from battery limits and available dwell time before selecting a model. Keep battery-side output and input-side losses separate in the energy calculation.

ONEPOINTECH Modules and Systems to Evaluate
Use these product references as starting points for an engineering review, not as universal recommendations by robot size. A higher nameplate rating does not help if the battery cannot accept the current or the installation cannot maintain the required coil position.
| Option | Published electrical reference | Integration checks |
|---|---|---|
| TE03 200W charging module | Datasheet output: 54.2V / 4A max, customizable. DC input: 48V / 6A. | Confirm the ordered output configuration, battery charging profile, receiver space and external DC supply. CAN / RS485 is on request. |
| TF02 800W charging module | Datasheet output: 54.2V / 15A, 800W max. DC input: 48V / 20A. | Check permitted battery current, thermal behavior and coil geometry. Confirm any requested CAN / RS485 configuration. |
| Complete 1.5kW, 3kW and 6kW systems | Model-specific output voltage and current limits. | Compare the complete system, site input power, component enclosure ratings, mounting arrangement and BMS interface. |
| Custom OEM integration | Requirements subject to feasibility review. | Provide battery data, drawings, charging windows and quantity where standard hardware does not fit. |
Hardware for engineering evaluation
Explore TE03 and TF02 modules
Review the module specifications against your battery and installation requirements. Standard configurations are available through the store for evaluation; OEM output and interface requirements need confirmation before ordering.
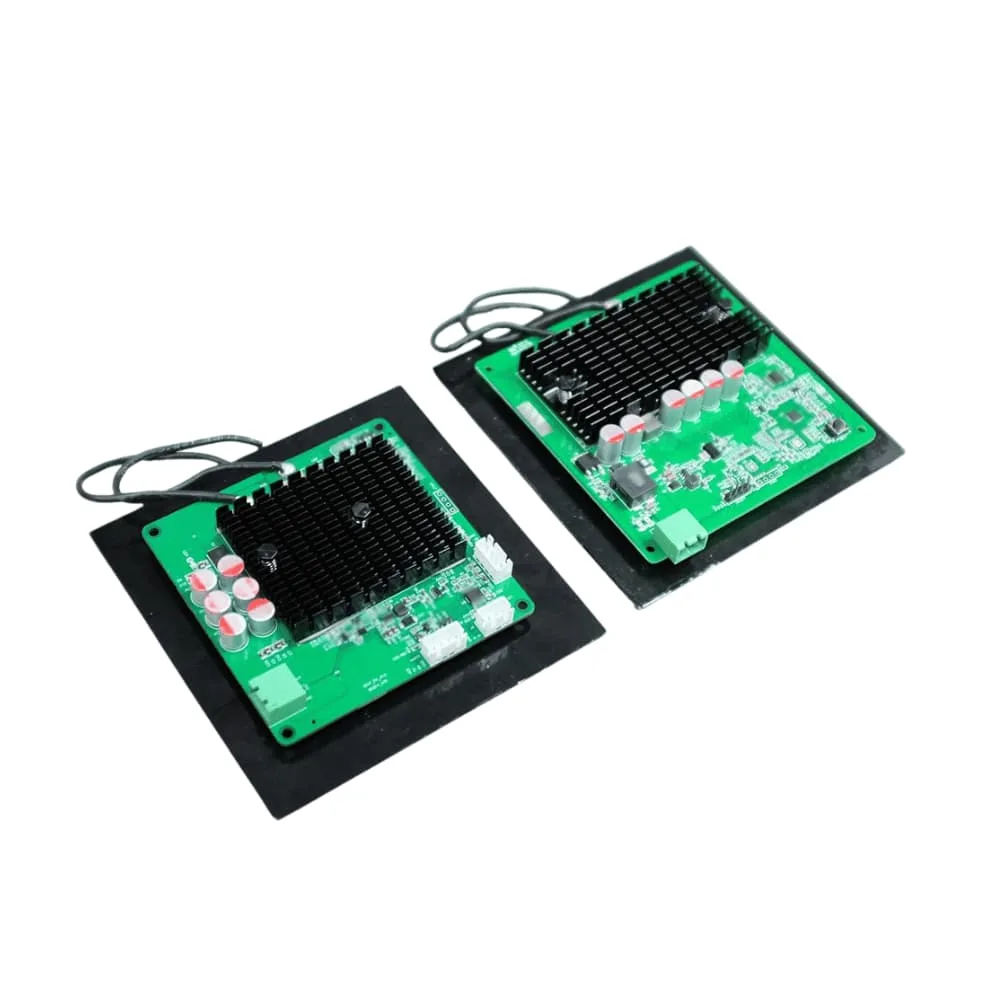
DC-input module
TE03 · 200W
Evaluate a compact transmitter and receiver set where the battery charging requirements and available dwell time fit its operating range.
- Confirm the selected output voltage and charging profile.
- Validate receiver space, coil position and DC supply.
- CAN / RS485 configuration is on request.
DC-input module
TF02 · 800W
Evaluate a higher-power module when the battery can accept the required charging current and the vehicle has space for the coils and thermal design.
- Check battery current limits and the ordered output configuration.
- Validate coil spacing and temperature at the intended duty cycle.
- CAN / RS485 configuration is on request.
A module is one part of the charging installation. Confirm battery/BMS compatibility, mounting, enclosure protection and controls before a pilot or fleet rollout.
OEM and fleet projects
Not sure which module fits?
Send your battery requirements, available charging window, mounting constraints and expected quantity. Our team can help evaluate a module, complete system or custom integration path.
Key Engineering Factors
1. Battery Voltage
Most AMR wireless charging projects start with battery voltage. Common battery systems include 24V, 36V, and 48V, but industrial robots may use other voltages depending on the drive system.
Specify nominal battery voltage separately from maximum charging voltage. Confirm chemistry, charge profile, permitted current and temperature limits with the battery supplier. A module selected for a nominal 24V or 48V pack is not automatically compatible with every pack in that voltage class.
2. Battery Capacity
Battery capacity determines how much energy the robot stores. A larger battery usually needs either more charging time or higher charging power. When planning an AMR wireless charging system, buyers should provide battery voltage, amp-hour rating, chemistry, maximum charging current, and expected operating schedule.
3. Air Gap
The air gap is the distance between the transmitter coil and receiver coil. A larger air gap usually makes power transfer harder and may reduce efficiency. The mechanical design should keep the charging distance as consistent as possible.
For AMRs, the air gap may be affected by ground clearance, wheel wear, suspension, floor flatness, docking structure, and receiver mounting position.
4. Alignment Tolerance
AMRs do not always stop in exactly the same position. A good wireless charging design should allow reasonable misalignment while still maintaining safe and efficient power transfer.
Alignment tolerance depends on coil size, coil shape, control design, and mechanical docking accuracy. If the robot has poor positioning accuracy, the charging station should include mechanical guides or a larger tolerance design.
5. Thermal Management
Wireless charging systems generate heat in the power electronics and coils. Thermal design is especially important when the receiver is installed inside a compact robot body with limited airflow.
Engineers should consider:
- Receiver module temperature
- Coil temperature
- Battery temperature
- Enclosure material
- Ventilation
- Charging current limit
- Ambient operating temperature
- Duty cycle
6. Communication
Some AMR wireless charging systems only provide power. Others include communication between the charger, robot controller, and battery management system.
Interfaces are model- and configuration-specific. Existing TE03 and TF02 product information lists CAN / RS485 on request; confirm the supplied interface and protocol before ordering. A connector or bus name alone does not establish BMS compatibility.
Communication can be used for:
- Start/stop charging
- Charging status
- Fault reporting
- Battery voltage/current data
- Temperature warnings
- System diagnostics
- Fleet management integration
7. Safety Protection
An industrial AMR wireless charger should be designed with protection features. Depending on the application, this may include:
- Overvoltage protection
- Overcurrent protection
- Short-circuit protection
- Over-temperature protection
- Foreign object detection
- Receiver detection
- Misalignment protection
- Automatic shutdown
- Soft start
- Communication fault handling
Where to Install the Receiver on an AMR
Receiver placement affects performance. The receiver should be installed where it can align with the transmitter consistently while staying protected from mechanical damage.

Common receiver mounting positions include:
| Mounting Position | Best For | Notes |
|---|---|---|
| Bottom-mounted receiver | Floor charging pads | Common for AMRs with enough ground clearance |
| Side-mounted receiver | Wall or vertical dock charging | Useful when floor clearance is limited |
| Rear-mounted receiver | Docking-style charging | Works when AMR backs into charging station |
| Custom embedded receiver | OEM robot design | Best for clean integration and compact design |
For new robot designs, wireless charging should be considered early. For retrofit projects, the supplier needs mechanical drawings, mounting space, battery data, and docking accuracy information.
When AMR Wireless Charging Makes Sense
AMR wireless charging is a strong fit when:
- Robots need automatic charging without human help
- The fleet operates for long hours or multiple shifts
- Charging contacts create maintenance problems
- The environment is dusty, wet, oily, or dirty
- The robot body needs a sealed design
- Short opportunity charging stops are available
- Manual charging creates labor cost or safety issues
- The AMR fleet needs higher uptime
- The customer wants less connector and cable wear
- The system needs a clean, professional charging interface
When Wireless Charging May Not Be Necessary
Wireless charging is not always required. A simple wired charger may be enough when:
- The robot fleet is small
- Robots are charged manually after each shift
- Low cost is more important than automation
- The working environment is clean and dry
- The robot does not need frequent charging
- Charging downtime does not affect operations
- The product has very limited space for coils or receiver electronics
The best decision depends on the cost of downtime, the required automation level, and the long-term maintenance burden.
AMR Wireless Charging Specification Checklist
Before asking for a quotation, prepare the following information. For station-level electrical, mechanical and environmental requirements, use the AMR charging station specification checklist.
| Requirement | What to Prepare |
|---|---|
| Robot type | AMR, service robot, warehouse robot, cleaning robot, inspection robot |
| Battery voltage | 24V, 36V, 48V, or custom |
| Battery capacity | Ah or Wh rating |
| Battery chemistry | Lithium, LiFePO4, lead-acid, or other |
| Charging power target | Desired wattage or target charging time |
| Maximum charging current | BMS or battery limit |
| Available air gap | Distance between transmitter and receiver |
| Alignment tolerance | Expected positioning accuracy |
| Receiver mounting space | Available length, width, height |
| Transmitter mounting method | Floor, wall, dock, side, or custom |
| Environment | Indoor, outdoor, wet, dusty, cleanroom, cold storage |
| Communication | Required interface, protocol, charge-enable signals and fault behavior; confirm availability for the selected model |
| Certification market | US, EU, UK, Japan, Korea, or other |
| Quantity | Sample, pilot run, or production |
| Timeline | Prototype schedule and production target |
Common Mistakes When Choosing AMR Wireless Charging
Mistake 1: Choosing Power Before Understanding Duty Cycle
A high-power charger is not always necessary. A lower-power system may work if the robot has enough idle time. But if the robot only stops for short periods, higher power may be required.
Mistake 2: Ignoring Alignment Tolerance
The charging system must match the robot’s real parking accuracy. If the AMR cannot stop consistently, the system may need a larger coil, docking guide, or better positioning logic.
Mistake 3: Treating Wireless Charging as Only an Electrical Problem
Wireless charging is both electrical and mechanical. Coil position, enclosure material, gap distance, heat, cable routing, and mounting structure all affect performance.
Mistake 4: Forgetting the BMS
The wireless charging receiver should not be selected without understanding the battery and BMS. The BMS may limit charging current, require communication, or control when charging can start and stop.
Mistake 5: Not Testing in the Real Environment
Factory floors are not perfect test benches. Dust, temperature, vibration, floor unevenness, and robot positioning accuracy should be tested before scaling to a fleet.
FAQ: AMR Wireless Charging
How does an AMR charge wirelessly?
The AMR parks near a transmitter pad or charging station. A receiver coil on the robot aligns with the transmitter coil, and power transfers across the air gap through electromagnetic induction. The receiver converts the power into DC output for the battery or BMS.
Does AMR wireless charging require precise alignment?
It requires alignment within the system’s designed tolerance. The exact tolerance depends on coil size, coil design, air gap, charging power, and control electronics. For industrial AMRs, alignment should be discussed early in the mechanical design.
Can wireless charging work with 24V and 48V AMR batteries?
Yes, wireless charging systems can be designed for different battery voltages, including 24V and 48V. The receiver output and charging profile must match the battery and BMS requirements.
Can wireless charging be used for opportunity charging?
Yes. Opportunity charging is one of the main reasons to use wireless charging for AMRs. The robot can charge during short stops without manual plugging or mechanical contact.
Is wireless charging safe for industrial AMRs?
A properly designed system should include protection features such as overcurrent, overvoltage, over-temperature, receiver detection, and foreign object protection. The system should also be designed for the certification and safety requirements of the target market.
Does wireless charging reduce maintenance?
It can reduce maintenance related to charging contacts, plugs, cables, and exposed connectors. This is especially valuable in dusty, wet, or high-use environments.
Can wireless charging be retrofitted into an existing AMR?
Yes, but it depends on available mounting space, battery system, ground clearance, docking accuracy, and electrical integration. Retrofit projects should begin with robot drawings, battery data, and charging workflow requirements.
What information is needed for an AMR wireless charging quotation?
At minimum, provide battery voltage, battery capacity, desired charging power, available charging time, air gap, alignment tolerance, receiver mounting space, environment, communication needs, quantity, and certification market.
Request an AMR Charging Integration Review
AMR wireless charging is not just a convenient charging method. For industrial mobile robots, it can become part of the automation strategy. By removing manual plugging and exposed charging contacts, wireless charging helps AMRs charge automatically during planned stops, reduce maintenance, and support higher fleet availability.
The right system depends on battery voltage, charging power, air gap, alignment tolerance, thermal design, BMS integration, and the real operating environment.
If you are designing a new AMR, retrofitting an existing robot, or planning an automated charging station for a robot fleet, ONEPOINTECH can help evaluate the transmitter, receiver, coil design, charging power, and integration requirements for your project.
Need help choosing an AMR wireless charging module or custom charging system?
Request a technical review for your OEM or fleet project. Send battery chemistry, nominal and maximum charging voltage, capacity, permitted charging current, available charging windows, receiver space, air gap, parking accuracy, required BMS interface, quantity and project stage. Our team can evaluate standard modules, complete systems or a custom development path.